Six useful questionsDescribe what you need from robotic conveyor tracking before choosing a solution
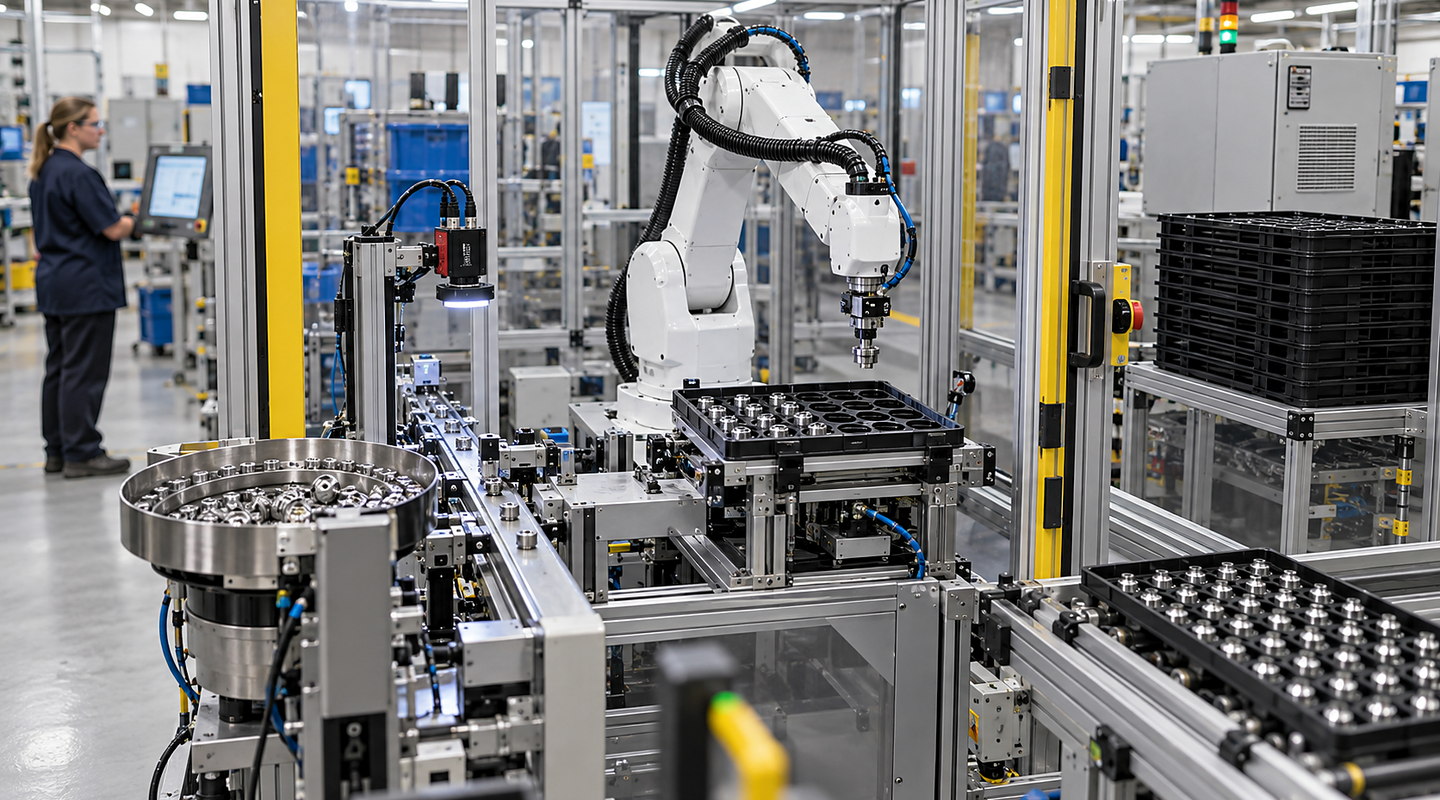
For repeatable production using robot picking from moving conveyors, share the normal condition, realistic range and difficult cases the finished system must handle.
Question 1Part, Product and Process Variation for Robot Picking From Moving Conveyors
Provide representative products, relevant drawings and revisions, and the normal range and credible extremes the system must handle. Include difficult examples so feasibility work reflects real product variation rather than a single nominal part.
Question 2Arrival Pattern and Presentation
Describe belt movement and variation in arrival position and spacing. Include gaps and overlapping items among the representative conditions, and identify the presentation and hand-off required by downstream operations.
Question 3Required Cycle and Production Pattern
State the required complete cycle and production pattern, supported by current observations. Include detection, tracking, gripping, downstream hand-off and recovery in the requirement rather than specifying robot movement speed alone.
Question 4Tooling, Sensing and Process Interfaces
Supply drawings and details of the proposed detection, tracking and gripping sequence and its line interfaces. List upstream and downstream states and external dependencies, separating confirmed information from assumptions that need review.
Question 5Operator Access, Recovery and Changeover
Describe missed-pick cases and the recovery needed when tracking is interrupted. Map operator, cleaning, maintenance and changeover access, and include normal, difficult and fault scenarios in the application assessment.
Question 6Run-Off Criteria and Production Evidence
Agree representative products and conveyor conditions, the trial method, repetitions and acceptable results. Specify the result record and reviewer, and the documentation, training, exclusions and controls needed when products or operating conditions change.